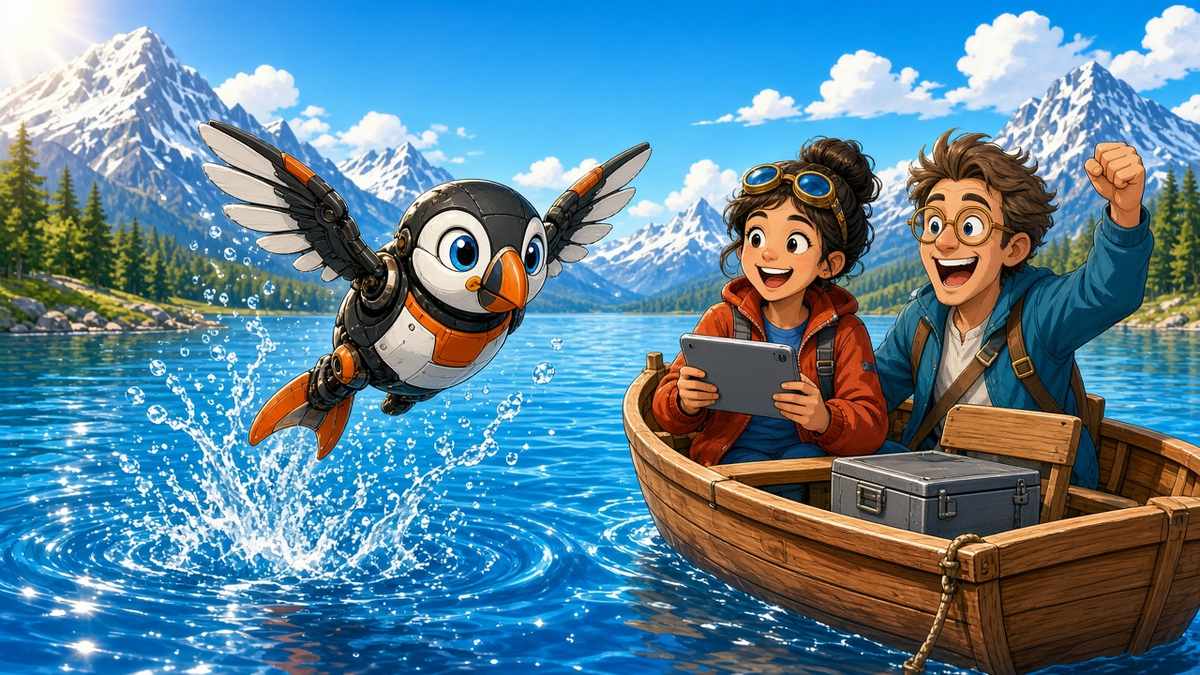
Gulls and puffins make it look easy: they plunge into the sea, paddle around underwater and then burst back into the air as if water and air were the same thing. For engineers, that trick has been surprisingly hard to copy, because water is about 1,000 times denser than air. Now a team from MIT and the Swiss university EPFL in Lausanne has built a small robot that can do it.
The machine is officially called a “flapping-wing aerial-aquatic vehicle”, or FAAV, but it is easier to think of it as a robo-puffin. It weighs less than 300 grams, roughly half a pound, and has a central body, two flexible wings and a steerable tail. Inside sit a battery and a waterproof electric motor that drives a crankshaft, pumping the wings up and down. The thin wing membranes are coated with water-repelling nanoparticles so they shed water quickly, and a motorised tail changes angle to help the robot climb or dive.
In tests in a water tank and on Lake Geneva, the team led by MIT assistant professor Raphael Zufferey searched for the right mix of wing size, flapping speed and tail angle. Medium-sized wings worked best: flexible enough to keep the flapping small underwater, yet stiff enough to stay airborne. A steep pitch of 70 degrees let the robot leap from water to air, and unlike real diving birds, it did not need feet to push off.
The researchers imagine launching such drones from a boat or the shore to fly out to an iceberg, a port or a pod of whales, dive in to take a measurement or a sample, and fly back with the data at a fraction of today’s cost. If that works outside the lab, ocean science could soon get a very small, very busy new helper.